Choose a switching power supply inductor by the inductance available in operation, the current waveform and the thermal conditions. A nominal µH value and one current rating are not enough. This guide works through a buck converter example, including an error that can halve the calculated inductance.
Define the converter and the ripple convention
The calculations below apply to an ideal, steady-state buck converter in continuous conduction mode (CCM), with a constant switching frequency and linear, constant inductance. The average inductor current equals the output current. Boost, inverting buck-boost, discontinuous operation and coupled multiphase designs need their own equations.
During the on interval, the inductor voltage is Vin − Vout; during freewheeling it is approximately −Vout in this ideal model. Integrating vL = L × di/dt over the on interval gives the peak-to-peak ripple ΔIpp. Here ΔIpp always means maximum current minus minimum current, not its half-amplitude.
D = Vout / Vin
ΔIpp = (Vin − Vout) × D / (f_s × L)
L = (Vin − Vout) × D / (f_s × ΔIpp)
Ipk = Iout + ΔIpp / 2
I_L,rms = sqrt(Iout² + ΔIpp² / 12)
The RMS expression follows by averaging the square of a triangular ripple around Iout. It does not describe burst-mode or transient waveforms. TI’s power-stage calculation note, SLVA477C, pages 2–3, provides the corresponding CCM ripple and peak-current framework. Our duty ratio here is explicitly ideal; it is not TI’s efficiency-adjusted duty estimate.
Recalculate the 12 V to 5 V example
Assume a 10.8–13.2 V input range, a regulated 5 V output, a 3 A load and a fixed 500 kHz switching frequency. As a design choice for this example, set the target peak-to-peak ripple to 0.9 A at nominal 12 V. This is a calculation exercise, not a measured converter or a validated component recommendation.
Vin = 12 V; Vout = 5 V; Iout = 3 A
f_s = 500 kHz; ΔIpp,target = 0.9 A
D = 5 / 12 = 0.416667
L = (12 − 5) × (5 / 12) / (500000 × 0.9)
  = 6.481481… µH
There is no additional factor of 2 in the denominator when ΔIpp is peak-to-peak. The old calculation produced about 3.24 µH by introducing that factor, then used ΔI/2 again when calculating the peak. Those definitions were inconsistent. Rounding 6.48 µH to a nominal 6.8 µH is only the start of screening.
Check input range and initial tolerance
Recalculate at each relevant input voltage. The following values assume constant L and ignore DC bias and temperature effects; the last row includes only a −20% initial inductance tolerance.
| Assumed input | Assumed inductance | Calculated ΔIpp | Interpretation |
|---|---|---|---|
| 12 V | 6.8 µH | 0.858 A | Nominal operating point |
| 13.2 V | 6.8 µH | 0.914 A | Already above the 0.9 A target |
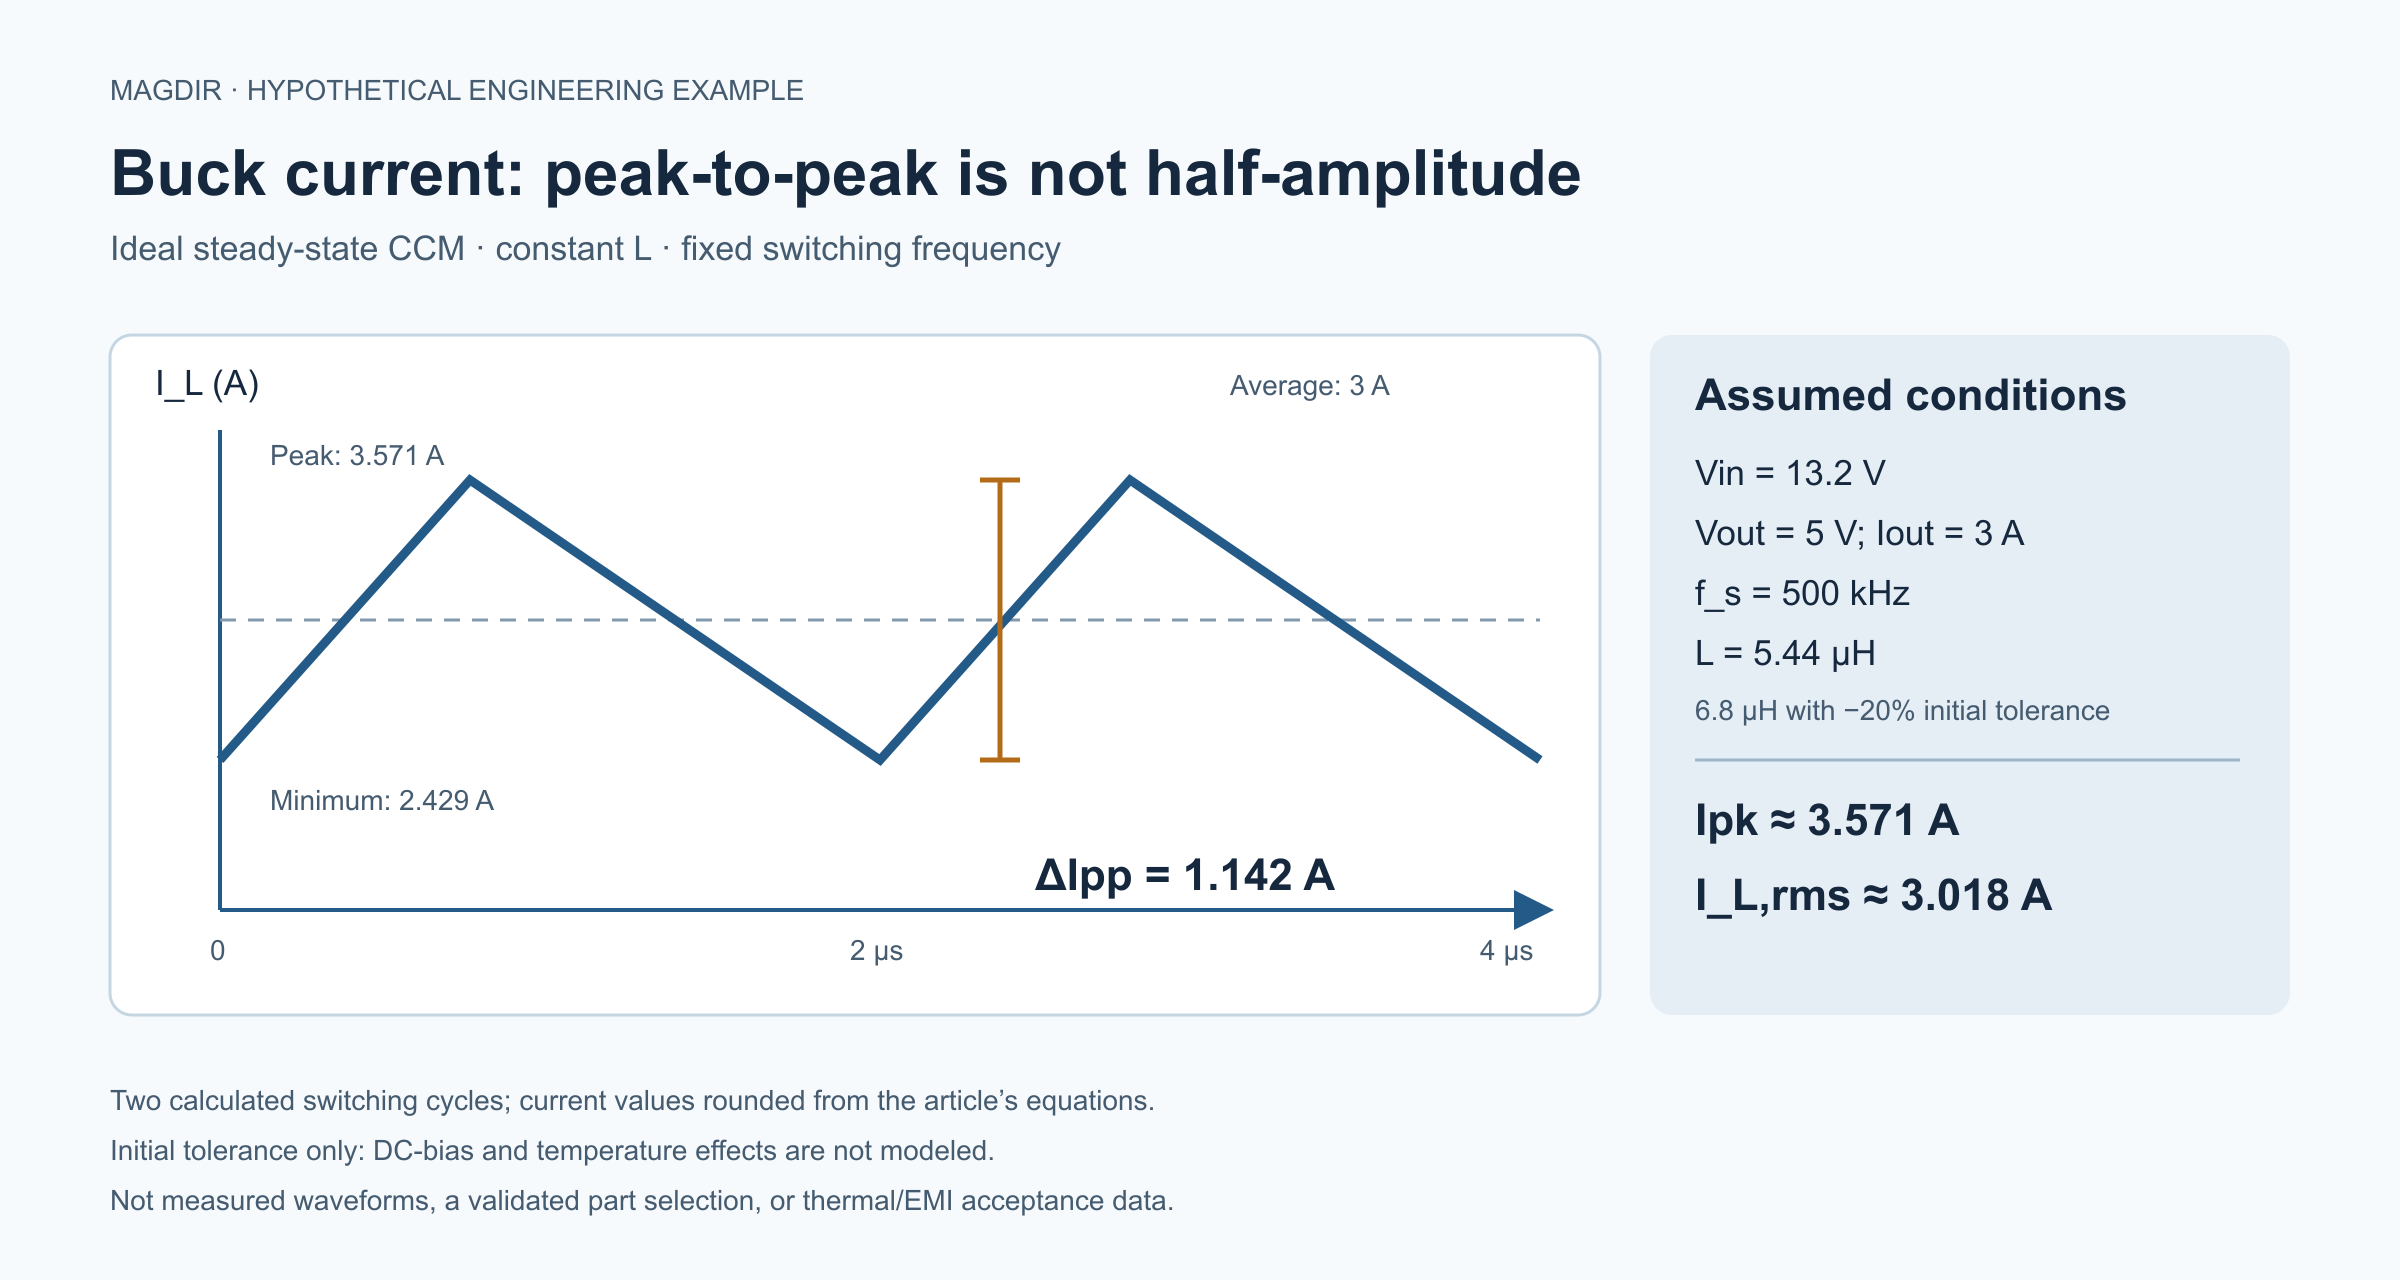
| 13.2 V | 5.44 µH | 1.142 A | Initial tolerance alone increases ripple further |
Thus the nominal 6.8 µH candidate has not met a 0.9 A maximum across the input range. Nor is 5.44 µH a guaranteed minimum in operation. Obtain L versus current and temperature data for the exact part, distinguish typical curves from guarantees, and recalculate with a defensible operating inductance. Use the controller’s minimum switching frequency if its frequency varies. Coilcraft’s selection guide explains why catalog values must be read with their test conditions.
Separate magnetic limits from heating
Use peak current to examine the L-versus-current curve and the manufacturer’s Isat definition. Use the actual RMS waveform and losses to assess heating. A datasheet rating labelled Irms is a current associated with a specified temperature-rise test; it is not a measurement of your circuit’s RMS current. These definitions and conditions are set out in Coilcraft’s current-rating note.
For the last table row, assume a constant winding resistance of 20 mΩ at the temperature being evaluated:
Vin = 13.2 V; L = 5.44 µH; Iout = 3 A; f_s = 500 kHz
ΔIpp = 1.141934… A
Ipk = 3.570967… A
I_L,rms = 3.018057… A
R = 20 mΩ
P_R = I_L,rms² × R = 0.182173… W
This is only the resistive-loss estimate under that assumption. Frequency-dependent winding loss and magnetic-core loss remain to be added with suitable manufacturer data. It does not establish temperature rise or converter efficiency. TDK’s power-inductor application note, in its loss section, distinguishes the winding and core contributions.
The normal-load peak is also not the fault peak. Check the controller’s guaranteed current-limit range, sensing method, delay, startup and recovery behavior. The minimum limit matters for delivering the load; the maximum limit and overshoot matter for component stress. A fixed multiplier on load current cannot replace those checks.
Turn a candidate into a verified choice
- Start with the controller’s recommended L and output-capacitor range and its control/compensation requirements. A larger L is not automatically compatible.
- Record the exact part number, tolerance, test frequency, bias and temperature curves, maximum DCR, Isat criterion, thermal-test setup, dimensions and temperature limits.
- Measure the inductor current at input/load extremes, startup and relevant transients. Confirm the current probe bandwidth, offset and peak behavior before comparing with the calculation.
- Check component temperature on the intended PCB and in the intended enclosure. Then assess output ripple, load response, efficiency and EMI at system level. Nominal inductance, magnetic shielding or an arbitrary SRF-to-switching-frequency ratio does not prove those results.
For terminology, see the inductor parameter guide. The inductor fundamentals guide explains the underlying component behavior. Actual controller/part selection and prototype acceptance still require engineering verification.
References and revision
- B1 — TI, Basic Calculation of a Buck Converter’s Power Stage: SLVA477C, December 2011, revised September 2026; pages 2–3, equations (2), (4), (5), and page 5 on component/compensation constraints.
- C1 — Coilcraft, Current and Temperature Ratings: Doc 361 HTML, checked 2026-10-29; current definitions and measurement methods.
- C2 — Coilcraft, Selecting the Best Inductor for Your DC-DC Converter: Doc 469 HTML, checked 2026-10-29; data-sheet interpretation and inductance.
- T1 — TDK, How to Use Power Inductors: official HTML, checked 2026-10-29; current ratings and winding/core loss sections.
Revision, 2026-10-29: corrected the peak-to-peak ripple convention, replaced unsupported part-selection claims with a reproducible buck example, and separated saturation, heating and validation. Original URL and publication date are retained in the source record. AI editorial self-review; no independent native-speaker engineer review or prototype test is claimed.